Body Electrical System
Description and Operation
In this manual: Body Electrical System
9steps
~54min
2/5difficulty
Done 0 of 9
System Overview
RPAS (Rear Parking Assist System) is an electronic driver assistance system that warns the driver to be careful when parking or in low-speed environments. The sensors use ultrasonic waves to detect objects within the proximity of the vehicle. The RPAS consists of four RPS sensors that detect obstacles and transmit the result, divided into three warning levels (first, second and third), to the BCM over the communication line. The BCM determines the warning level from the communication message transmitted by the slave sensors, and then activates the buzzer or transmits data for display.
- INITIAL Mode
- The system initialization time is 500 ms after IGN1 + R gear.
- RPAS recognizes the LID and sets the sensor identifier during initialization.
- RPAS activates each sensor and then performs diagnosis after BCM initialization is completed.
- The R-PAS start buzzer operates normally when the sensor does not send an error message and after the error diagnosis is completed.
- If any sensor failure is received, the R-PAS start buzzer does not operate, but the warning signal operates momentarily. If the vehicle has a display option, a warning symbol is also displayed on it.
- The sensor failure buzzer sounds once, but the display remains continuously illuminated until the fault is fully rectified.
- Normal Mode
- LIN communication starts and continues the procedure after IGN1 ON+R.
- The BCM sends a operation request message once to each sensor to check the initial system status, and the four sensors are activated simultaneously. At this time, if there are no problems, the alarm starts after 500 ms of shifting into R, at 300 ms intervals.
- After initialization, normal mode starts 100 ms after the alarm output is completed.
- The obstacle warning is divided into 3 levels. The first and second levels sound intermittently, and the third level sounds continuously.
- The effective vehicle speed for RPAS operation is less than 10 km/h.
- Refer to "Digital PAS LIN Communication" for more detailed communication specifications.
- Setting Mode
- In principle, the start conditions are the same as in NORMAL MODE, and use the TUNING TOOL as the MASTER instead of the BCM MASTER.
- Therefore, the BCM is not connected to the LIN bus.
- The TUNING TOOL displays the analog path after receiving reference and conversion data in the LIN communication diagnostic frame format with the sensors.
- Refer to "Digital PAS Project_LIN_communication" for more detailed communication specifications.
- Configuration Mode
- The purpose of CONFIGURATION MODE is as follows.
A. Check the assigned ID for each sensor B. Check the variant ID for each sensor - In principle, the start conditions are the same as in NORMAL MODE, and use the TUNING TOOL as the MASTER instead of the BCM MASTER.
- Therefore, the BCM is not connected to the LIN bus.
- The SETUP TOOL checks and assigns the supplier ID and function ID.
- Refer to "Digital PAS Project LIN Communication" for more detailed communication specifications.
- The purpose of CONFIGURATION MODE is as follows.
- Measurement conditions: PVC pole (diameter 75 mm, length 1 m), normal temperature.
- Distance to detected object (measured directly in front of the sensor): 61 cm (24.0 in.) ~ 120 cm (47.2 in.): ± 15 cm (5.9 in.); 31 cm (12.2 in.) ~ 60 cm (23.6 in.): ± 15 cm (5.9 in.); less than 30 cm (11.8 in.): ± 10 cm (3.9 in.)
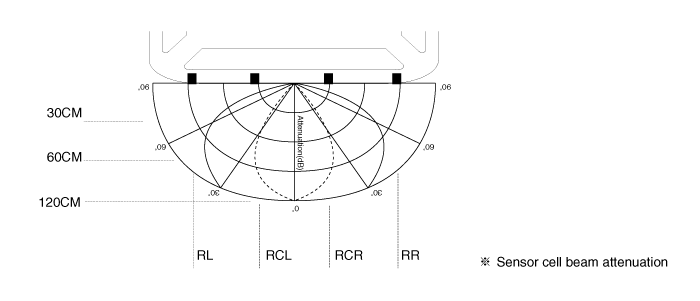
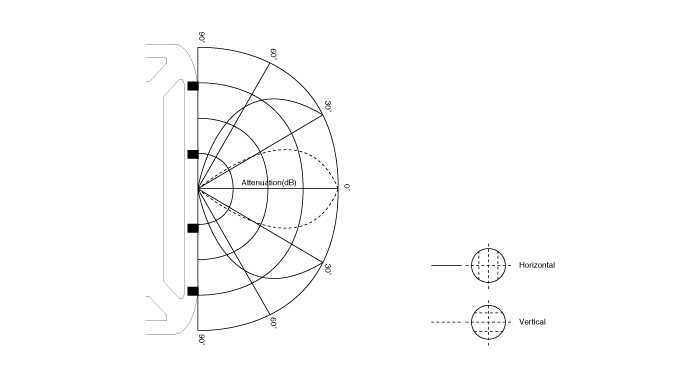
Direct measurement
Transmission and reception are performed by one sensor (RL, RCL, RCR, RR for each sensor configuration).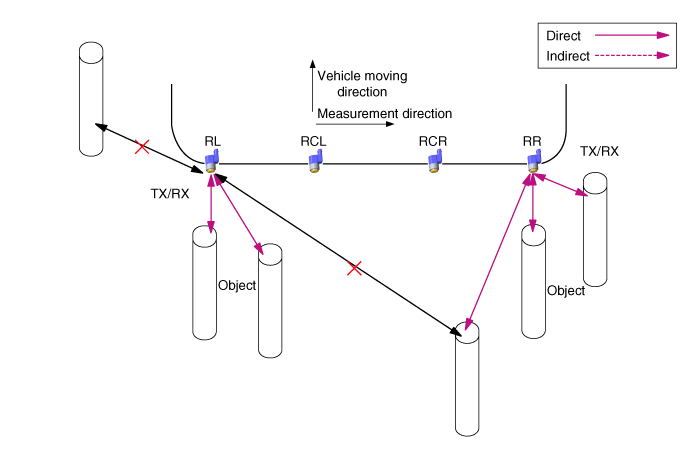
Indirect measurement
(RCL > RL, RCL > RCR, RCR > RCL, RCR > RR, performed in order) With two or three sensors, one sensor transmits while the others receive.
Direct and indirect measurement at the same time
With two or three sensors, one sensor performs both transmission and reception, and the others perform reception only.
- Buzzer and display processing method of BCM. In case of RL/RR sensor information, BCM processes each sensor information directly for the display and buzzer output function. For CL/CR sensor output, BCM processes the information as a center combination, with priority given to both sensors.


- First warning zone (61 cm~120 cm)

- Second warning zone (31 cm~80 cm)
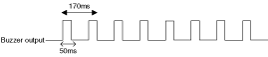
- Third warning zone (less than 30 cm)
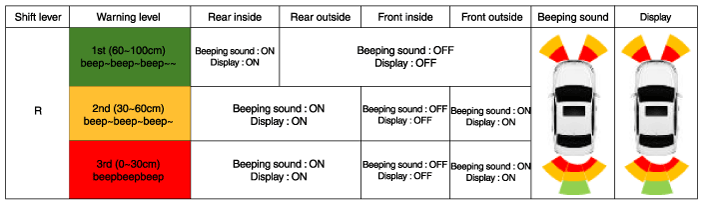
- It only indicates the obstacle detection position.
- At the third warning level, the indicator flashes at one-second intervals.
- When the normal alarm level is displayed, the RCR/RCL indicators are combined by priority.
Test yourself
A quick Hyundai Sonata LF quiz: every answer comes with an explanation and a link to the manual page.
Was this page helpful?