System Description
SYSTEM DESCRIPTION
BRIEF DESCRIPTION
(a) The Controller Area Network (CAN) is a serial data communication system for real-time applications. It is a vehicle multiplex communication system with high communication speed and a malfunction detection function.
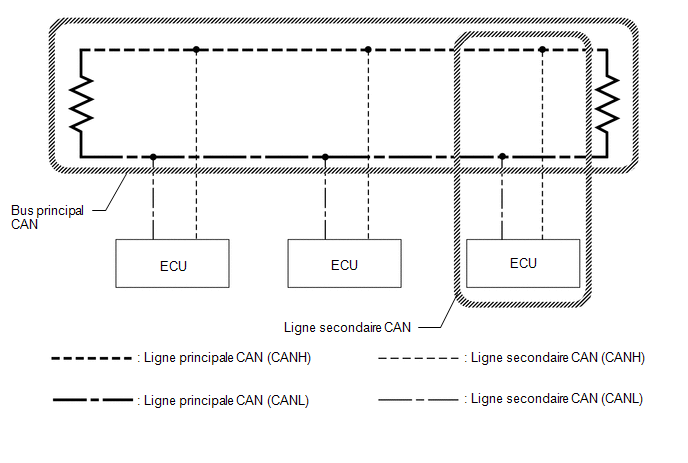
(b) Using the CANH and CANL bus line pair, CAN communication is established using a differential voltage. (A reference voltage is applied to the line pair, and a differential voltage is created during communication.)
(c) Many sensors or ECUs on the vehicle operate by sharing information and communicating with each other.
(d) Two resistors, which are required for communication, are used in the main CAN bus line.
TERM DEFINITIONS
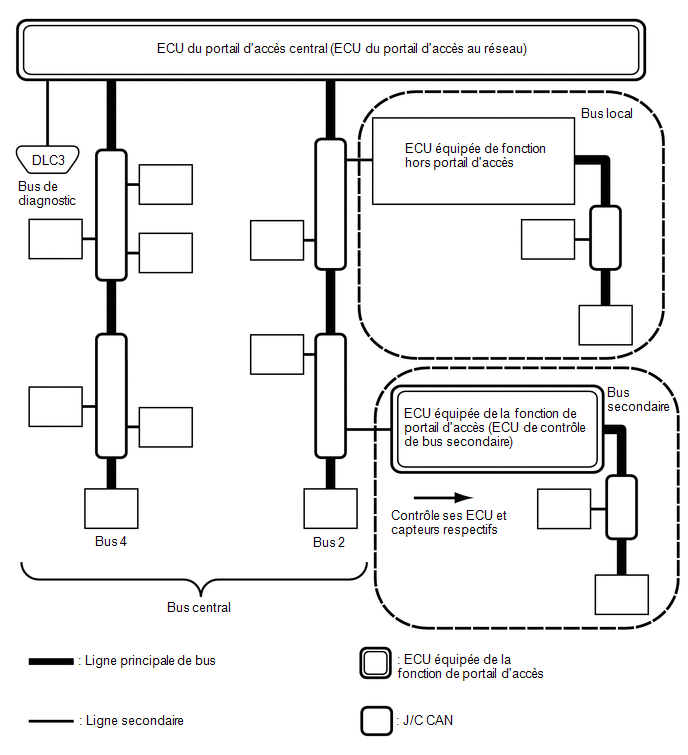
(a) Central Bus
(1) The central bus is a term used to describe all buses directly connected to the central gateway ECU (network gateway ECU).
HINT:
A bus is displayed as a bus on the "Communication Bus Check" screen of the Techstream.
(b) Sub-bus
(1) A sub-bus is a bus that has a gateway function ECU in order to communicate with the central bus and other sub-buses.
HINT:
- A sub-bus is displayed as a sub-bus on the "Communication Bus Check" screen of the Techstream.
- When a sub-bus is selected on the "Communication Bus Check" screen, ECUs and sensors connected to networks other than CAN, such as LIN networks, may also be displayed in addition to the ECUs and sensors connected to the CAN network sub-buses.
(c) Local Bus
(1) A local bus is a bus that cannot communicate with other buses. ECUs and sensors on a local bus communicate only with other ECUs and sensors on the same bus.
(d) CAN J/C
(1) A CAN junction connector is a connector that allows the branch lines to be connected to a main bus.
(e) Main Bus
(1) A main bus line is the wire harness that connects the 2 terminating resistors of a bus.
(f) Branch
(1) A branch bus line is a wire harness that connects the ECU and sensor to a main bus line.
(g) Terminating Resistors
(1) Terminating resistors that keep the signal stable in the CAN bus are installed. Two 120 Ω resistors, one at each end of the bus, are required.